AUTONOMOUS SEARCH AND RESCUE DRONE WITH REAL-TIME YOLO OBJECT DETECTION AND GPS NAVIGATION USING RASPBERRY PI 4
Authors
-
Ulpan Turmaganbet
 PhD student, Department of Physics and Technology, al-Farabi Kazakh National University, Almaty, Kazakhstan
-
Dana Turlykozhayeva
PhD, Researcher, Lecturer, Department of Physics and Technology, al-Farabi Kazakh National University, Almaty, Kazakhstan
-
Sayat Akhtanov
PhD, Researcher, Senior Lecturer, Department of Physics and Technology, al-Farabi Kazakh National University , Almaty, Kazakhstan
-
Symbat Temesheva
PhD student, Department of Physics and Technology, al-Farabi Kazakh National University, Almaty, Kazakhstan
-
Nurzhan Ussipov
PhD, Researcher, Lecturer, Department of Physics and Technology, al-Farabi Kazakh National University, Kazakhstan
-
Mingliang Tao
PhD, Researcher, Professor, School of Electronics and Information, Northwestern Polytechnical University, Xian, China
DOI:
https://doi.org/10.31489/2026N3/116-125Keywords:
Unmanned aerial vehicles, search and rescue, object detection, computer vision, autonomous navigation, embedded systems, real-time processingAbstract
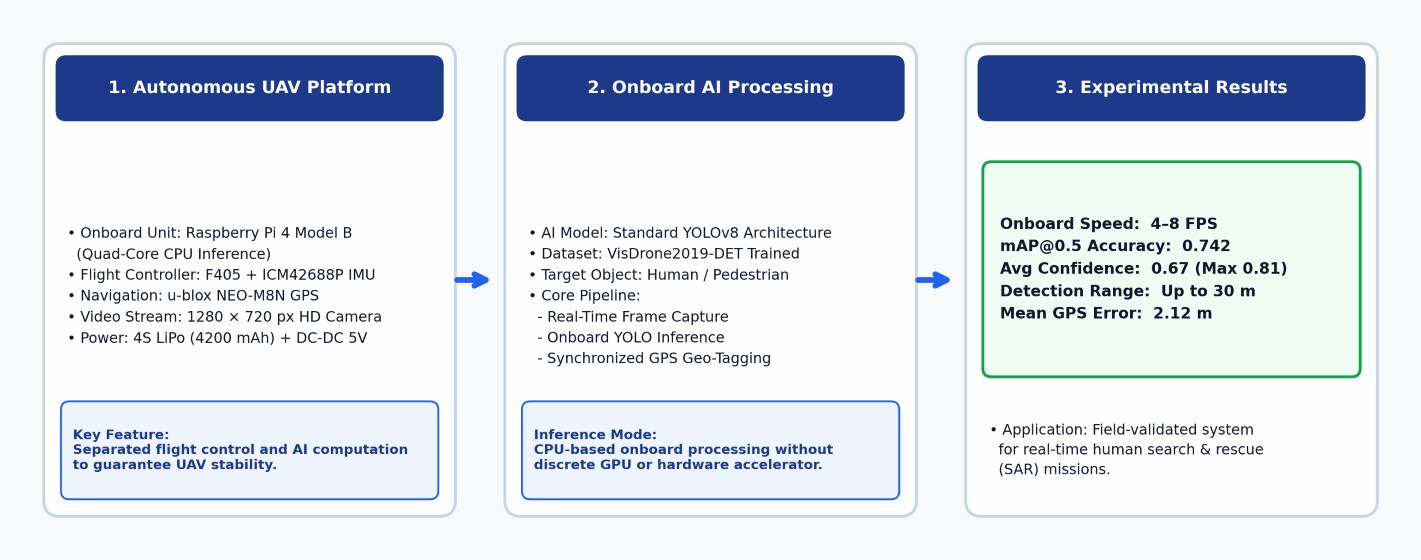
The development of intelligent unmanned aerial vehicles with onboard computer vision capabilities is increasingly relevant to search and rescue operations. However, real-time human detection on compact UAV platforms remains challenging due to limited computational resources, varying environmental conditions, and the small size of distant targets. This study presents a UAV-based human detection and localization system integrating a Raspberry Pi 4 Model B, YOLOv8, and u-blox NEO-M8N GPS. The system performs onboard processing of the video stream and associates detected targets with the UAV's geographical position. The YOLOv8 model was trained using the VisDrone2019-DET dataset and evaluated through real-world flight experiments under different distances, altitudes, and lighting conditions. The system achieved an average detection confidence of 0.67, with a maximum confidence of 0.81, and a real-time processing speed of 4–8 FPS. Human targets were detected at distances of up to 30 m, while GPS positioning errors ranged from 1.6 to 2.8 m, with a mean error of approximately 2.12 m. The results demonstrate the capability of the proposed UAV platform to perform onboard human detection and GPS-based localization in real-time, providing a basis for UAV-assisted search and rescue applications.
References
1 line
Ciccone, F., & Ceruti, A. (2025). Real-Time Search and Rescue with Drones: A Deep Learning Approach for Small-Object Detection Based on YOLO. Drones, 9(8), 514. https://doi.org/10.3390/drones9080514 DOI: https://doi.org/10.3390/drones9080514
Vaman Ravi Prasad, D. A. S. U., & Reddy, P. (2025). Autonomous Human Detection Using Drones in Search and Rescue Operations. SSRN. https://dx.doi.org/10.2139/ssrn.5232204 DOI: https://doi.org/10.2139/ssrn.5232204
Jayalath, K., & Munasinghe, S. R. (2021). Drone-based autonomous human identification for search and rescue missions in real-time. In 2021 10th Intern. Conference on Information and Automation for Sustainability (ICIAfS) (pp. 518-523). IEEE. https://doi.org/10.1109/ICIAfS52090.2021.9606048 DOI: https://doi.org/10.1109/ICIAfS52090.2021.9606048
Ho, Y.-H., & Tsai, Y.-J. (2022). Open Collaborative Platform for Multi-Drones to Support Search and Rescue Operations. Drones, 6(5), 132. https://doi.org/10.3390/drones6050132 DOI: https://doi.org/10.3390/drones6050132
Lyu, M., Zhao, Y., Huang, C., & Huang, H. (2023). Unmanned aerial vehicles for search and rescue: A survey. Remote Sensing, 15(13), 3266. https://doi.org/10.3390/rs15133266 DOI: https://doi.org/10.3390/rs15133266
Zhao, B., Zhao, J., Song, R., Yu, L., Zhang, X., & Liu, J. (2025). Enhanced YOLO11 for lightweight and accurate drone-based maritime search and rescue object detection. PLOS ONE, 20(7), e0321920. https://doi.org/10.1371/journal.pone.0321920 DOI: https://doi.org/10.1371/journal.pone.0321920
Vaidya, S. K., Sakthivel, V., Majumdar, R., Gupta, P., Jeevan, S., Prakash, P., & Selvamuthukumaran, T. (2026). A virtual testbed for maritime search and rescue: Customizing YOLO for small object detection in unreal engine. Journal of Ocean Engineering and Science. https://doi.org/10.1016/j.joes.2025.12.018 DOI: https://doi.org/10.1016/j.joes.2025.12.018
Abdelnabi, A. A. B., & Rabadi, G. (2024). Human detection from unmanned aerial vehicles’ images for search and rescue missions: A state-of-the-art review. IEEE Access, 12, 152009-152035. https://doi.org/10.1109/ACCESS.2024.3479988 DOI: https://doi.org/10.1109/ACCESS.2024.3479988
Mishra, A., Narendra, M., Sinha, A., & Kumar, A. (2025). Dynamic Backbone Optimization of YOLOv10 for Real-Time Object Detection in UAV-Based Search and Rescue Missions. IEEE Access, 13, 195975-195986. https://doi.org/10.1109/ACCESS.2025.3633379 DOI: https://doi.org/10.1109/ACCESS.2025.3633379
Khashush, N. A., Radif, M. J., & Abdalrdha, Z. K. (2025). A review of smart drone technologies for security surveillance and search and rescue. Journal of Al-Qadisiyah for Computer Science and Mathematics, 17(4), 155-173. https://doi.org/10.29304/jqcsm.2025.17.42549 DOI: https://doi.org/10.29304/jqcsm.2025.17.42549
Temesheva, S. A., Turlykozhayeva, D. A., Akhtanov, S. N., Ussipov, N. M., Zhunuskanov, A. A., Sun, W., & Tao, M. (2026). A Comprehensive Review of Metaheuristic Algorithms for Node Placement in UAV Communication Networks. Sensors (Basel, Switzerland), 26(3), 869. https://doi.org/10.3390/s26030869 DOI: https://doi.org/10.3390/s26030869
Turmaganbet, U., Zhexebay, D., Turlykozhayeva, D., Skabylov, A., Akhtanov, S., Temesheva, S., & Tao, M. (2025). Thermal infrared object detection with yolo models. Eurasian Physical Technical Journal, 22(2), 121–132. https://doi.org/10.31489/2025N2/121-132 DOI: https://doi.org/10.31489/2025N2/121-132
Šiktar, L., Ćaran, B., Šekoranja, B., & Švaco, M. (2025, June). Autonomous uav navigation for search and rescue missions using computer vision and convolutional neural networks. In International Conference on Robotics in Alpe-Adria Danube Region (pp. 661-669). Springer Nature Switzerland. https://doi.org/10.1007/978-3-032-02106-9_73 DOI: https://doi.org/10.1007/978-3-032-02106-9_73
Tran, H. K., Le, V. T., Tran, T. T., & Nguyen, V. D. (2025). Low-Cost Remotely-Operated Vehicle Navigation with GPS and RF Lora Integration. Archives for Technical Sciences, 2(33), 297-306. http://dx.doi.org/10.70102/afts.2025.1833.297 DOI: https://doi.org/10.70102/afts.2025.1833.297
Schedl, D. C., Kurmi, I., & Bimber, O. (2021). An autonomous drone for search and rescue in forests using airborne optical sectioning. Science Robotics, 6(55), eabg1188. https://doi.org/10.1126/scirobotics.abg1188 DOI: https://doi.org/10.1126/scirobotics.abg1188
Du, D., Zhu, P., Wen, L., Bian, X., Lin, H., Hu, Q., & Liu, Z. (2019). VisDrone-DET2019: The vision meets drone object detection in image challenge results. In 2019 IEEE/CVF International Conference on Computer Vision Workshop (ICCVW), 213-226. IEEE. https://doi.org/10.1109/ICCVW.2019.00030 DOI: https://doi.org/10.1109/ICCVW.2019.00030
Jocher, G., Chaurasia, A., & Qiu, J. (2023). Ultralytics yolo. Zenodo. https://github.com/ultralytics/ultralytics
Downloads
Published online
How to Cite
Issue
Section
License
Copyright (c) 2026 Eurasian Physical Technical Journal

This work is licensed under a Creative Commons Attribution-NonCommercial-NoDerivatives 4.0 International License.